AK80-9 V3.0 KV100 without driver
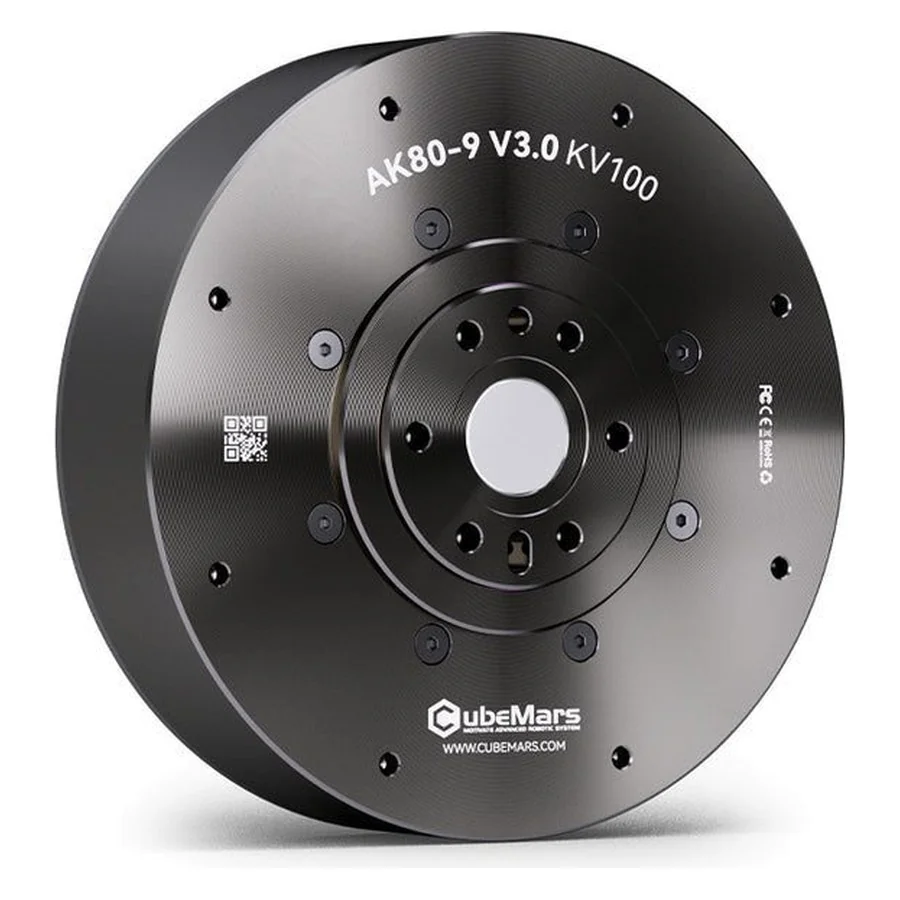
AK Series. 9 N·m rated, 22 N·m peak, Ф98 mm, 490 g, 9:1 reduction, 48 V.
US$537.00
9 N·m rated and 22 N·m peak from a Ф98 x 38.5 mm, 490 g frame, geared 9:1, on 48 V. Kv 100, 390 RPM rated and 570 RPM no-load. CubeMars lists it for legged robots, exoskeletons and AGVs.
This is the without driver configuration.
The current revision of the AK80-9: 16-bit encoder, an NTC temperature sensor the original does not have, and more current headroom (28 A peak against 22.3 A) in the same 98 mm envelope.
Import duty on US orders is on us. Freight is charged once per order, not per item, and shipping is free on orders of US$200 or more — see the rates.
Driver board
Specifications
| Reduction Ratio | 9:1 |
|---|---|
| Rated Torque (N·m) | 9 |
| OD (mm) | 98 |
| Weight (g) | 490 |
| Peak Torque (N·m) | 22 |
| Rated Voltage (V) | 48 |
| Rated Speed (RPM) | 390 |
| No-Load Speed (RPM) | 570 |
| Rated Current (A) | 12 |
| Peak Current (A) | 28 |
| Maximum Torque Density (N·m/kg) | 44.9 |
| Height (mm) | 38.5 |
| Backlash (arcmin) | 15 |
| Back Drive (N·m) | 0.51 |
| Kv (RPM/V) | 100 |
| Kt (N·m/A) | 0.095 |
| Ke (V/kRPM) | 10 |
| Phase to Phase Resistance (mΩ) | 160 |
| Phase to Phase Inductance (μH) | 116 |
| Rotor Inertia (g·cm²) | 579 |
| Motor Constant (N·m/√W) | 0.2387 |
| Mechanical Time Constant (ms) | 0.725 |
| Pole Pairs | 21 |
| Number of Slots | 36 |
| Winding Type | Delta |
| Number of Encoder | 1 |
| Inner Loop Encoder Type | Magnetic Encoder |
| Inner Ring Encoder Resolution | 16bit |
| UART Connector | A1257WR-S-3P |
| Power Connector | XT30PW-M |
| Temperature Sensor | NTC MF51B 103F3950 |
| Noise dB (65cm away the motor) | 60 |
| Basic Dynamic Load Rating Cr (N) | 2760 |
| Basic Static Load Rating C0r (N) | 2810 |
| Operation Ambient Temperature | -20℃~50℃ |
| Insulation Level | C |
| Driving Way | FOC |
| Application | Legged Robot, Exoskeleton, AGV |