AK70-9 V3.0 KV60 with driver
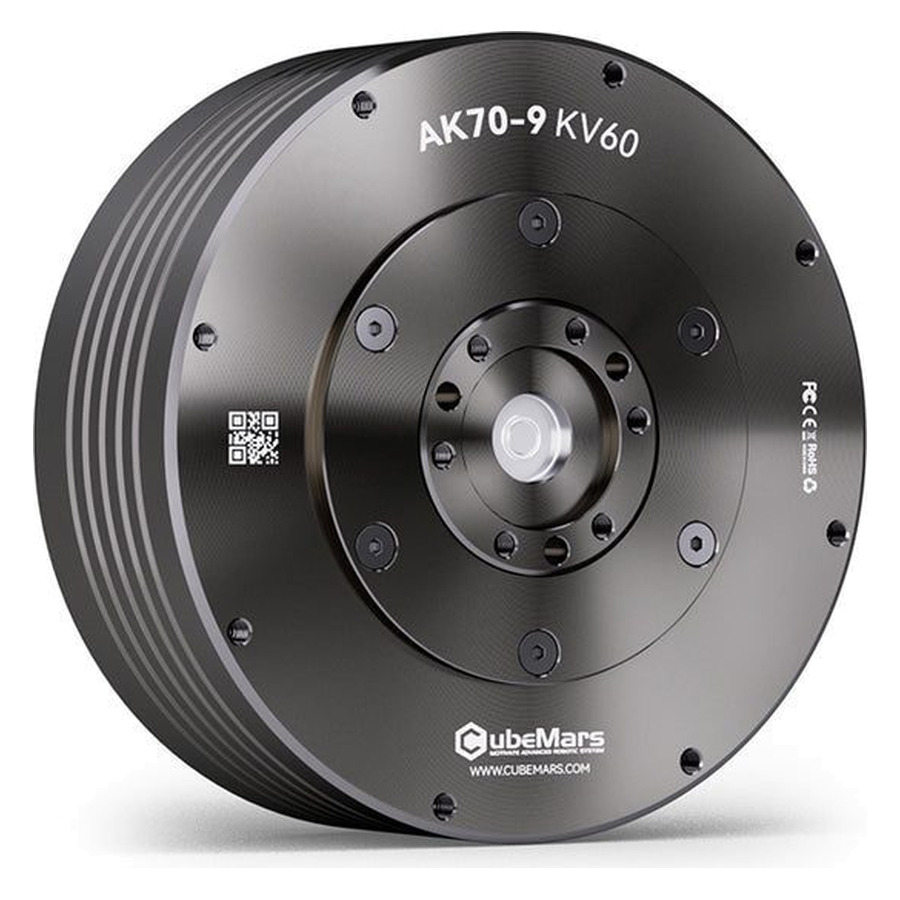
AK Series. 8.5 N·m rated, 29.2 N·m peak, Ф89 mm, 540 g, 9:1 reduction, 48 V.
US$559.00
This is the with driver configuration.
The mid-size V3.0 joint, at the ratio where a planetary reducer stops costing much speed — 9:1 on an 89 mm frame. Legs, shoulders, and anything that has to move as well as hold. Supplied with the driver board fitted.
Driver board
Specifications
| Reduction Ratio | 9:1 |
|---|---|
| Rated Torque (N·m) | 8.5 |
| OD (mm) | 89 |
| Weight (g) | 540 |
| Peak Torque (N·m) | 29.2 |
| Rated Voltage (V) | 48 |
| Rated Speed (RPM) | 260 |
| No-Load Speed (RPM) | 320 |
| Rated Current (A) | 6.25 |
| Peak Current (A) | 23.8 |
| Maximum Torque Density (N·m/kg) | 54 |
| Height (mm) | 49 |
| Backlash (arcmin) | 18 |
| Back Drive (N·m) | 0.8 |
| Kv (RPM/V) | 60 |
| Kt (N·m/A) | 0.159 |
| Ke (V/kRPM) | 16.7 |
| Phase to Phase Resistance (mΩ) | 475 |
| Phase to Phase Inductance (μH) | 408 |
| Rotor Inertia (g·cm²) | 450 |
| Motor Constant (N·m/√W) | 0.23 |
| Mechanical Time Constant (ms) | 1.7 |
| Pole Pairs | 21 |
| Number of Slots | 24 |
| Winding Type | Delta |
| Number of Encoder | 2 |
| Inner Loop Encoder Type | Magnetic Encoder |
| Inner Ring Encoder Resolution | 14bit |
| Outer Ring Encoder Type | Magnetic Encoder |
| Outer Ring Encoder Resolution | 15bit |
| CAN Connector | A1257WR-S-4P |
| UART Connector | A1257WR-S-3P |
| Power Connector | XT30PW-M |
| Temperature Sensor | NTC MF51B 103F3950 |
| Noise dB (65cm away the motor) | 50 |
| Basic Dynamic Load Rating Cr (N) | 1890 |
| Basic Static Load Rating C0r (N) | 2140 |
| Operation Ambient Temperature | -20℃~50℃ |
| Insulation Level | C |
| Driving Way | FOC |
| Application | Legged Robot, Exoskeleton, AGV |